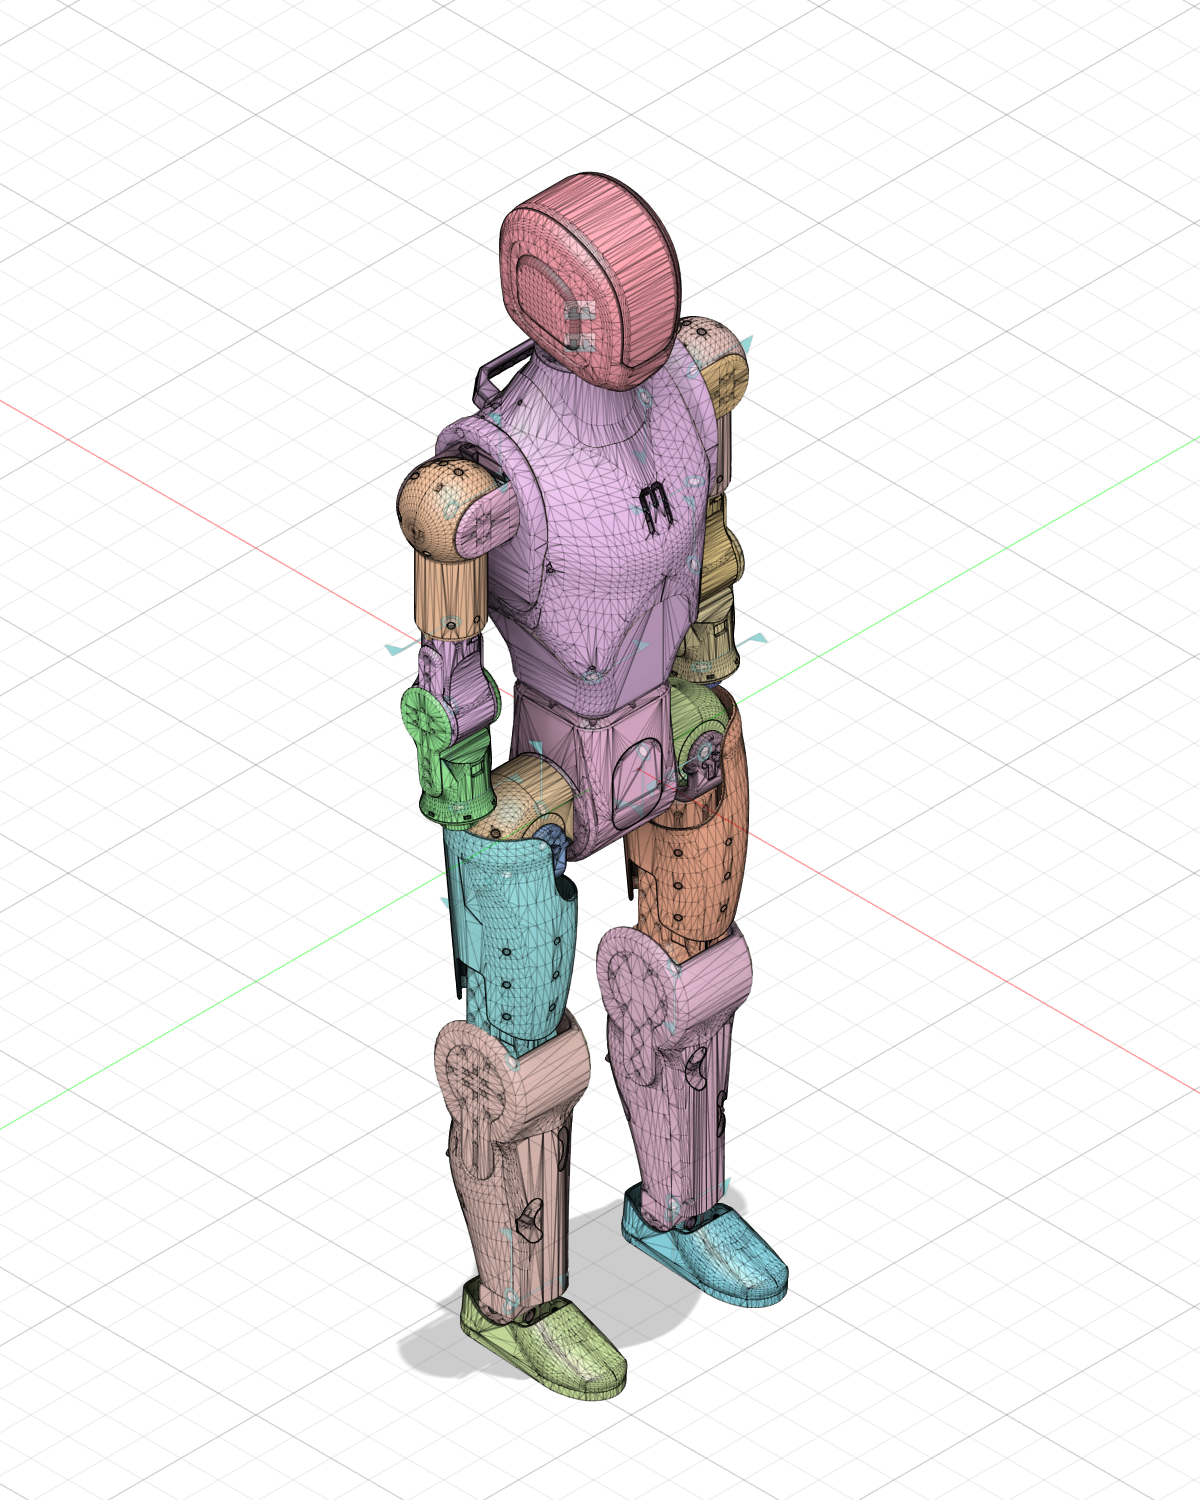
Asimov v1 is a 1.2 m, ~35 kg open-source humanoid robot with 25 degrees of freedom, designed by Asimov / Menlo Research.
What is on this page:
• Asimov_v1_Full_Robot_jointed.f3d – Fusion design with all 26 links and the 23 revolute joints set up as as-built motor joints with the real joint limits (hips, knees, ankles, waist, shoulders, elbows, wrists) plus the 2 neck joints. Open it in Fusion, grab a limb and drive it, or use Drive Joints / Motion Study to pose the robot.
• Asimov_v1_Right_Arm_jointed.f3d – the right arm on its own with shoulder, elbow and wrist joints, handy for testing.
• Asimov_v1_full_body_preview.stl – lightweight full-body mesh (home pose) for the 3D preview.
• Asimov_1.STEP – the complete original full-body STEP assembly (≈520 MB, SolidWorks export, Y-up).
• Asimov_v1_sim_model_URDF_MJCF.zip – URDF + MuJoCo MJCF with 25 link meshes for ROS / MuJoCo / Isaac simulation.
• ASV1_Bearings_Assembly.pdf – bearing assembly drawing.
Want to build one? The printable PA12 parts and fabrication STEP files are split by body section – see the seven "Asimov v1 – section" listings in the Robotics category. The original design uses MJF-printed PA12 for plastic parts plus CNC 7075 aluminium and 316L stainless parts; our print service can quote MJF/SLS for the PA12 parts.
Licence: CERN Open Hardware Licence v2 – Strongly Reciprocal (CERN-OHL-S-2.0). Original design by Asimov / Menlo Research (github.com/menloresearch/asimov-1). The Fusion files on this page are our conversion of their CAD and are shared under the same licence. If you distribute modified versions you must publish their sources under CERN-OHL-S as well. Not affiliated with or endorsed by the original authors.