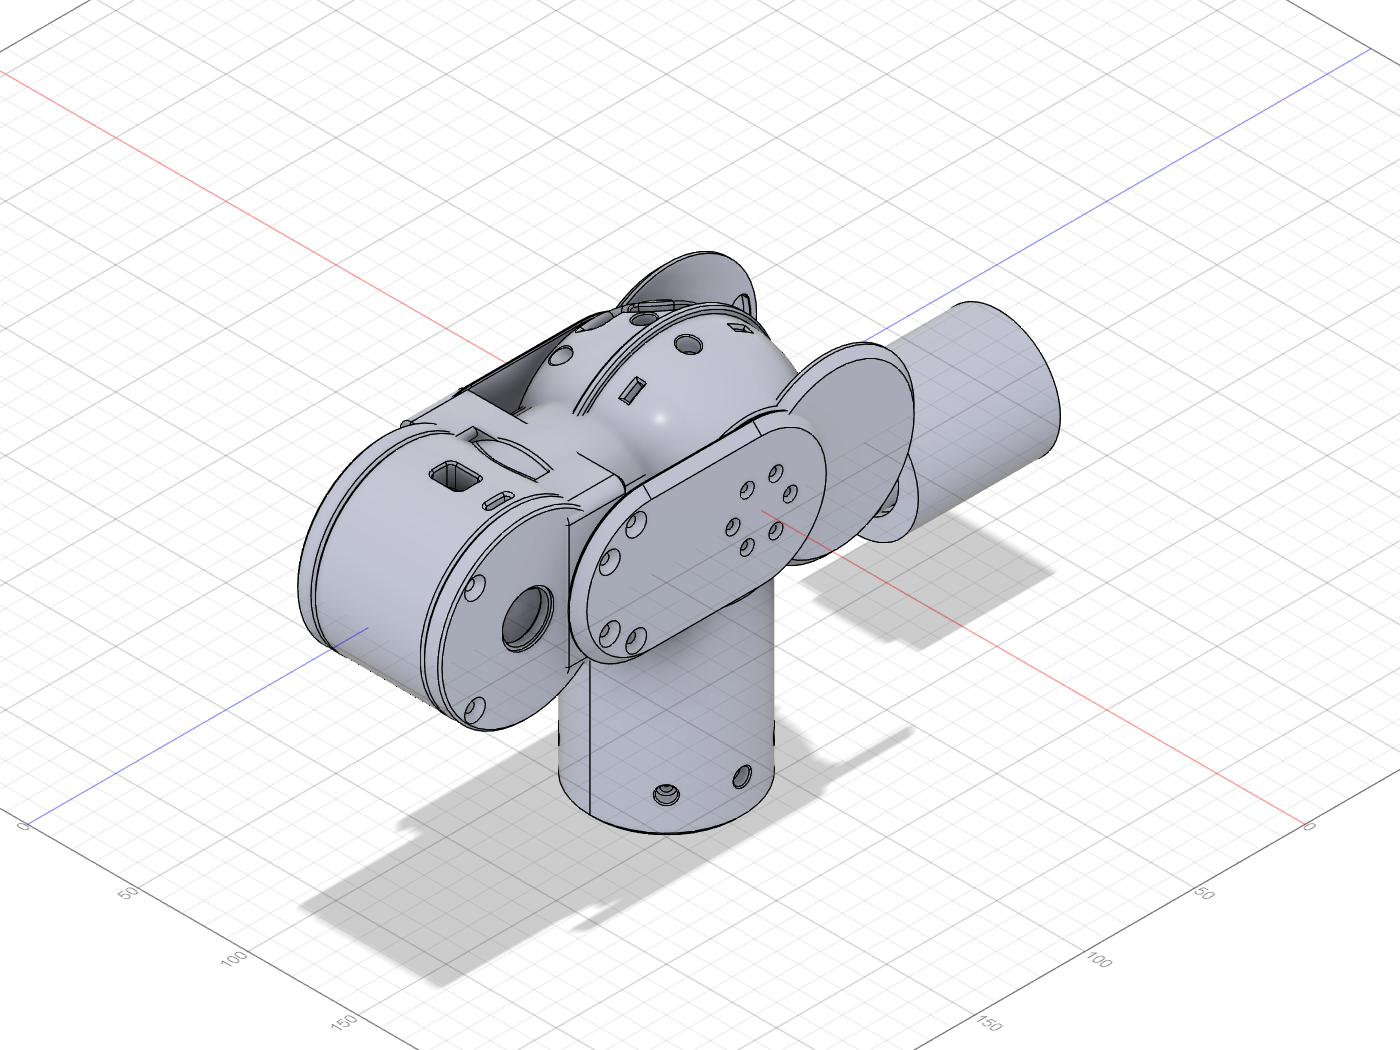
Section 300 (left arm) of the Asimov v1 open-source humanoid: shoulder pitch/roll/yaw, elbow and wrist links.
• 4 print-ready STLs – the parts the original design makes in MJF PA12 (ASV1_300_xxC), converted from the official STEP files. Best printed in PA12 by MJF/SLS; for FDM prototypes use PETG or PA-CF with 4+ perimeters and 40%+ infill.
• Asimov_v1_300_Left_Arm.f3d – Fusion design of the whole section, assembled in place.
• Asimov_v1_300_STEP_parts.zip – every fabrication STEP in the section, sorted by process (ALU_7075 CNC, MJF_PA12, SML_316L sheet/machined, OFF_THE_SHELF motors, bearings and fasteners), with the thread and heat-insert drawings.
The full jointed robot is in the "Asimov v1 Open-Source Humanoid – Full Robot" listing.
Licence: CERN Open Hardware Licence v2 – Strongly Reciprocal (CERN-OHL-S-2.0). Original design by Asimov / Menlo Research (github.com/menloresearch/asimov-1). The Fusion files on this page are our conversion of their CAD and are shared under the same licence. If you distribute modified versions you must publish their sources under CERN-OHL-S as well. Not affiliated with or endorsed by the original authors.